← back to work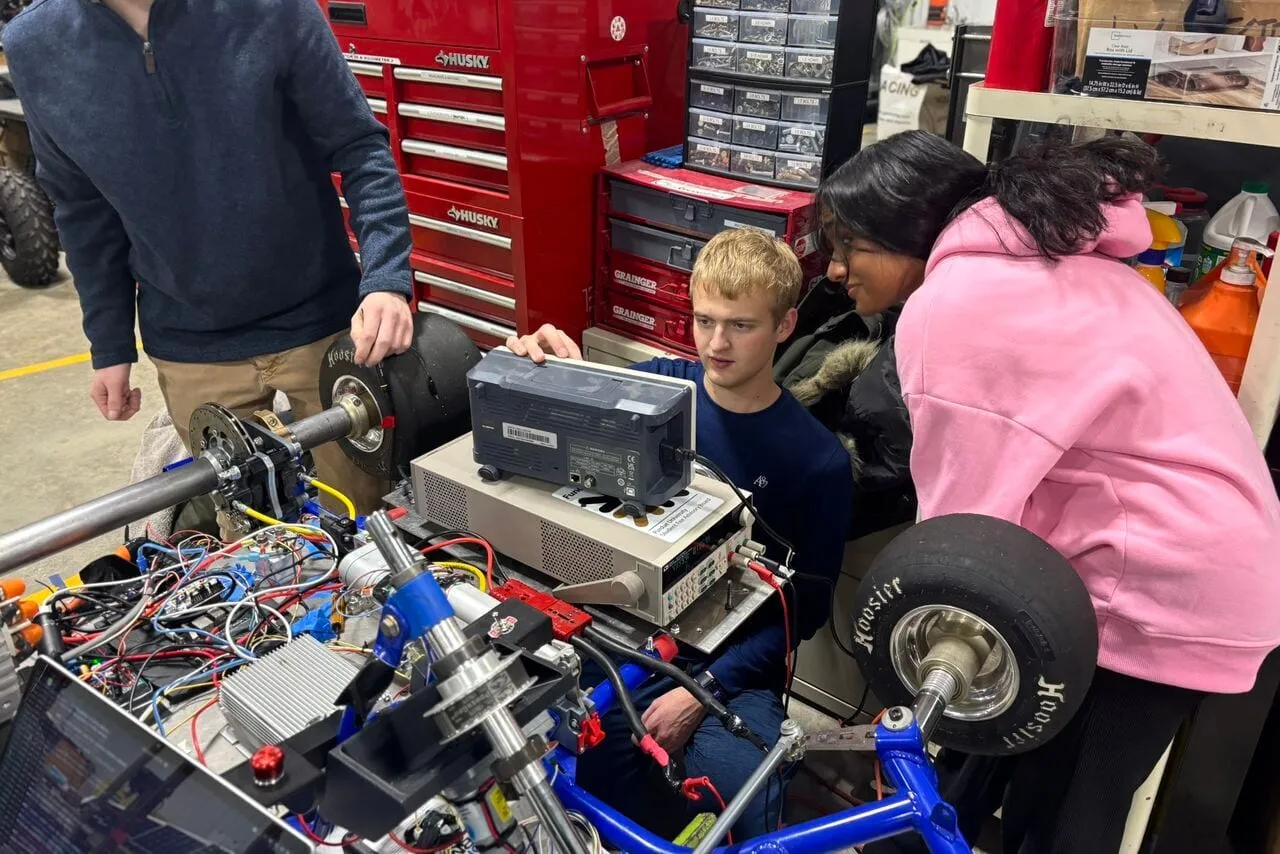
EVC go-kart vision
Python and OpenCV perception for an autonomous go-kart. Our team placed 1st of 9 international teams at the 2026 AKS US National Grand Prix.
- role
- Computer Vision Team
- team
- Electric Vehicle Club (EVC), Purdue University
- year
- 2025–26
- stack
- Python, OpenCV
Problem
Purdue’s Electric Vehicle Club builds an autonomous electric go-kart to race in the Autonomous Karting Series. I was on the three-person computer vision team, which turned the kart’s camera feed into track data for the team that planned the racing line.
What I did
- Wrote a Python and OpenCV pipeline that finds the edges of the track in each frame, using color filtering, edge detection and a top-down warp of the image, then fitting lines to trace the curves.
- Estimated the hidden edge on sharp turns, when only one side of the track is in view, from the visible edge and the track’s known width.
- Output the angle to each side of the track, which the racing team used to choose the line.
- Optimized it to run in real time on the kart’s onboard Jetson.
- Worked in a codebase shared across the club’s teams, using Git and Docker.
Result
- The team placed 1st of 9 teams from the US and Canada at the 2026 Autonomous Karting Series US National Grand Prix.
- The kart was also 1st in qualifying, with the fastest lap (1:03).
What I’d change
I’d get more involved with the other teams. The better I understood the rest of the kart, the better I could have tuned the vision system for it.